
魏俊
时间:2026-09-16 来源: 作者: 访问量:
一、基本情况
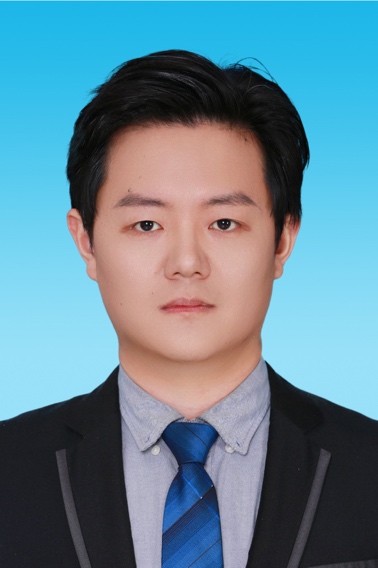
魏俊,男,博士,副教授,硕士生导师。毕业于天津大学机械工程专业,一直致力于机器人机构学、变胞/可重构机构与机器人、外骨骼机器人、折纸机器人及复杂系统动力学与控制等相关方向研究;主持并参与河北省自然科学基金项目,河北省教育厅项目,国家自然科学基金重点、创新研究群体等项目8项;在机器人机构学领域发表论文30余篇(SCI/EI检索),获得国家发明专利12项,合著出版学术著作《可重构机构与可重构机器人——分岔演变的运动学分析、综合及其控制》;兼任中国自动化学会机器人智能专业委员会委员,以及担任多家权威学术期刊的审稿人。
二、硕导所属(含跨转)学科、专业学位类别
机械工程学科(或专业学位类别)
研究方向1:可重构机构与机器人,折纸机器人
研究方向2:外骨骼机器人,机器人关节
研究方向3:复杂系统动力学及控制。
三、近年来发表代表性论文情况(仅限第一作者或通讯作者),主编或参编的教材、专著情况,获得专利情况等
1.发表代表性论文情况( * 通讯作者)
(1)期刊论文
[1] A. Y. Shi, J. J. Zhang, J. Wei*, C. L. Liu, W. L. Lv, J. K. Song, S. J. Guo, (2026). A motion manifold transmission switching-based type synthesis method for multi-operational-mode parallel mechanisms with configurable moving platforms, Mechanism and Machine Theory,224, 106433.
[2] Wei, J.*, Ai, C., Li, X., Song, J., Zhang, J., & Guo, S. (2026). A Passive Backpack Exoskeleton Based on a Four-Bar-Sinusoidal Coupled Mechanism for Centroid Regulation and Load Reduction. Journal of Mechanisms and Robotics, 18 (3), 031008
[3] Liu, C., Zhang, J., Wei,J.*, Zhao, X., Shi, A., Song, J., & Guo, S. (2026). Multi-level evolutionary design of targeted rigid-flexible parallel rehabilitation robot. International Journal of Mechanical Sciences, 111201.
[4] Song, J., Zhang, J., Wei, J.*, Liu, C., Zhao, X., & Ai, C. (2026). Development and Kinematics Optimization of a Human-Compatible Rope-Driven Ankle Rehabilitation Robot Based on Foot-Ankle IFHA Identification. IEEE transactions on bio-medical engineering, 73(1), 40-53.
[5] Liu, T., Zhao, Y., Tian, X., Huang, S., Wei, J., & Chen, Y. (2025). Optimization-free dimensional synthesis of planar 2R-3R parallel mechanisms based on a one-dimensional algebraic manifold. Mechanics Based Design of Structures and Machines, 1-26.
[6] Ai, C., Zhang, J., Wei, J.*, Song, J., Liu, C., & Shi, A. (2025). Configuration design and assisting effect evaluation of a novel double-support closed-chain unpowered load-carrying exoskeleton based on variable pivot gait. Robotica, 43(10), 3657-3681.
[7] J Wei*, Y Zhu, et al. Configuration representation in conformal geometric algebra for reconfigurable mechanisms. Mechanism and Machine Theory, 2025, 215: 106180.
[8] Y Xing, J Wei*, Y Zhu,et al. Lie algebra-based high-order constraint analysis of a novel multi-loop metamorphic mechanism derived from four-bar linkage for lower limb exoskeletons. Mechanism and Machine Theory, 2025, 209: 105994.
[9] J Song, J Zhang, J Wei*, et al. Kinematics Characteristic Analysis of a Type of Human-Machine Compatible Ankle Rehab Robots Based on Human-ankle IFHA Identification[J]. Robotics and Autonomous Systems, 2025, 104911.
[10] J Song, J Zhang, J Wei, et al. Configuration design and dimensional synthesis of a novel 4-DOFs parallel ankle rehabilitative robot with dual virtual motion center. Robotica, 2025,1-23.
[11] H Yang, X Liu, W Lv, Y Xia, J M Liu, J Wei, et al, Design and analysis of a reconfigurable origami tube with tunable load-bearing capacity, Thin-Walled Structures, 2024, 205:112452.
[12] W Lv, W Nie, J Wei*, et al. A novel construction method for 1-DOF multi-loop kirigami mechanisms. Mechanism and Machine Theory, 2024, 200: 105698.
[13] J Wei* S Zhang, J Zhang. Biofusion design and parameter optimization for a novel passive assisted knee exoskeleton robot based on eight-bar mechanism[J]. Robotica, 2024,42(6): 1959-1985.
[14] C Ai, J Wei*, et al. Variable Pivot Gait Based a Novel Dynamics Correction Method for Human Lower Limbs Model. Journal of Biomechanical Engineering, 2024 146 (4).
[15] J Song, J Wei, B Yu, et al. Configuration Design and Kinematic Performance Analysis of a Novel 4-DOF Parallel Ankle Rehabilitation Mechanism with Two Virtual Motion Centers. Chinese Journal of Mechanical Engineering, 2023, 36(154).
[16] D Zhang, Z Li, P Jia, Y Zheng, S Liu, J Wei, M Zhang. Optimization Design and Trajectory Error Compensation of a Facade-Adaptive Wall-Climbing Robot. Symmetry, 2023, 15(2): 255.
[19] J Zhang, Z Ma, J Wei*, S Yang, C Liu, S Guo. A Novel Evaluation Index and Optimization Method for Ankle Rehabilitation Robots Based on Ankle-Foot Motion. Journal of Biomechanical Engineering, 2023, 145(5): 051006.
[20] 魏俊,贾维涵,刘承磊,张建军,黄海晶,郭士杰. 驱动支链完全解耦的可重构踝关节康复并联机构型综合.机械工程学报,2022, 9(58), pp 45-56.
[21] W An, J Wei, X Lu, JS Dai, Y Li. Geometric Design-based Dimensional Synthesis of A Novel Metamorphic Multi-fingered Hand with Maximal Workspace. Chinese Journal of Mechanical Engineering, 2021, 34(1):1-15.
[23] J Wei, J S Dai. Reconfiguration-Aimed and Manifold-Operation Based Type Synthesis of Metamorphic Parallel Mechanisms with Motion between 1R2T and 2R1T. Mechanism and Machine Theory.2019,139: 66-80.
[24] Y Dong, J Wei. Output feedback stabilization of nonlinear discrete-time systems with time-delay. Advances in Difference Equations, 2012, 2012(1): 73.
[25] J Wei, Y Dong, Y Su. Guaranteed cost control of uncertain TS fuzzy systems via output feedback approach. WSEAS Transactions on Systems, 2011, 10(9): 306-317.
(2)会议论文
[1] Guan, Y., Liu, H., Zhu, Y., Xing, Y., & Wei, J.*. Design and Analysis of a Metamorphic Mechanism Derived from Planar Four-Six-Bar Linkages. In ICMD: 2025 International Conference on Mechanical Design. Singapore: Springer Nature Singapore, 2025: 1081-1089.
[2] J Wei*, H Ni, J Zhang. Conformational Design and Kinematic Analysis of a Reconfigurable Ankle Rehabilitation Robot. 2024 6th International Conference on Reconfigurable Mechanisms and Robots (ReMAR). IEEE, 2024: 479-486.
[3] Z Liu, J Wei, Y Xing, J Song and J Zhang. IMU-based continuous prediction of human lower limb joint angles, 2024 IEEE International Conference on Mechatronics and Automation (ICMA), Tianjin, China, 2024, pp. 1194-1199.
[4] J B Wang, L Ni, J Wei, J X Liu, J J Zhang, S J Guo. Active Disturbance Rejection Control of Lower Limb Exoskeleton Based on Genetic Algorithm. In 2023 42nd Chinese Control Conference (CCC), pp. 4407-4412. IEEE, 2023.
[5] K C, Qi, K F Fu, J Wei*, C L Liu, J K Song, and J J Zhang. Kinematics Analysis of the Wearable Waist Rehabilitation Robot. International Conference on Intelligent Robotics and Applications, pp. 164-175. Singapore: Springer Nature Singapore, 2023.
[6] Z X, Zhang, B Yu, J B Wang, J K Song, Jun Wei*. Configuration Synthesis of 4 DOF Knee Rehabilitation Parallel Mechanism Based on Multiset Theory. In International Conference on Intelligent Robotics and Applications, pp. 15-24. Singapore: Springer Nature Singapore, 2023.
[7] W Jia, C Liu, J Wei, J Zhang. Configuration Synthesis of Multi-mode Ankle Rehabilitation Robot. Intelligent Robotics and Applications: 14th International Conference, ICIRA 2021, Yantai, China, October 22–25, 2021, Proceedings, Part IV 14. Springer International Publishing, 2021: 103-114.
[8] J Wei, JS Dai. Group Method for Synthesis of Metamorphic Parallel Mechanism with 1R2T and 2R1T Reconfiguration. 2018 International Conference on Reconfigurable Mechanisms and Robots. IEEE, 2018: 1-6.
[9] J Wei, Y Dong, Y Su. Exponential stabilization for uncertain TS fuzzy systems with time-delay and nonlinear perturbation. Proceedings of the 31st Chinese Control Conference. IEEE, 2012: 1330-1335.
[10] Y Su, Y Dong, J Wei. Robust stability criterion for uncertain neural networks with time delay. Proceedings of the 31st Chinese Control Conference. IEEE, 2012: 524-529.
2. 出版专著情况
戴建生、康熙、宋亚庆、魏俊. 可重构机构与可重构机器人——分岔演变的运动学分析、综合及其控制, 北京:高等教育出版社,2021. 获得国家科学技术学术著作出版基金资助出版.
3. 主持/参与项目情况
[1] 河北省自然科学基金面上项目,下肢失能辅助外骨骼变胞机构刚柔耦合稳态变形机理研究,E2025202110,6万元,在研,2025.01-2027.12.
[2] 河北省高等学校科学研究青年基金项目,膝关节康复人机运动协同机构型综合研究,QN2025222, 5万元,在研,2025.01-2027.12.
[3] 深圳市智能机器人与柔性制造重点实验室开放课题项目,高适应性机构进化形态学机构综合与设计,ZDSYS20220527171403009,5万元,结题,2024.10-2025.10.
[4] 河北省自然科学基金面上项目,可重构并联机构多构型切换机理和运动特性协同研究,E2022202130,10万元,结题,2022.01-2024.12.
[5] 国家自然科学基金重点项目,机构演变与变胞机理及其面向任务的多工况性能综合设计,51535008,398万元,结题,2016.01-2020.12.
[6] 国家自然科学基金创新研究群体项目,高端装备机构理论与技术基础,51721003,1050万元,结题,2018.01-2023.12.
4. 发明专利情况
[1] 魏俊,钱涵阳,迟福龙. 一种刚柔耦合变胞膝关节,中国发明专利:CN 122275063 A,2026.04.09.
[2] 魏俊, 刘鸿飞, 官永鹏. 一种外骨骼运行模态切换用的过渡控制方法, 中国发明专利:CN 121879103 A, 2026.4.17.
[3] 魏俊, 官永鹏. 一种具有部分可展性能和大可展比的可重构可展机构, 中国发明专利:CN 120666828 A,2025.09.19
[4] 魏俊, 朱宇航, 邢宇松, 官永鹏, 张建军, 郭士杰. 一种髋关节变胞组件和康复外骨骼变胞机构,中国发明专利: CN119734247A, 2025-04-01
[5] 魏俊,官永鹏, 刘鸿飞, 朱宇航, 张建军, 郭士杰. 一种膝关节变胞助力外骨骼.中国发明专利:CN119188707A,2024.12.27.
[6] 魏俊,邢宇松,刘泽坤,朱宇航,张建军.一种辅助支撑的多位姿变胞外骨骼.中国发明专利:CN118357900A,2024.07.19.
[7] 魏俊,张忠鑫,张建军等. 一种四自由度膝关节康复并联机构,中国发明专利, CN116672213A,2023.09.01.
[8] 魏俊,倪海东,张建军等. 一种可重构的踝关节康复并联机构,中国发明专利,CN116350473A,2023.06.30.
[9] 刘承磊,高德義,张建军,魏俊,郭士杰.一种刚柔耦合踝关节康复机器人.中国发明专利: CN116869782A,2023.10.13.
[10] 张建军,高德義,刘承磊,魏俊,郭士杰.一种踝关节运动识别机构.中国发明专利: CN116982971A, 2023.11. 03.
[11] 张建军,于斌,魏俊,刘承磊等. 一种新型含子闭链的四自由度踝关节康复并联机构,中国发明专利,授权号:CN114668629B, 2024.1.12.
[12] 李咪,魏俊,戴建生. 一种新型变胞并联铰链机构, 授权号:CN111136644A,国家发明专利,2020.5.12.
联系邮箱:jun.wei@hebut.edu.cn , 欢迎机械、控制、数学背景的考生报考。
1